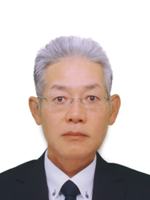
深見 公一郎 (フカミ コウイチロウ)

Fukami Koichiro

写真a

職名

准教授

科研費研究者番号

50399424

研究室住所

沖縄県中頭郡西原町千原1番地

メールアドレス

メールアドレス

ホームページ

https://www.agr.u-ryukyu.ac.jp/department/sub-regional

プロフィール

大学時代は,オフロード地盤における車両と土の力学的相互作用(テラメカニックス)に関する研究に携わっていました。農研機構に就職してからは,沖縄県の重粘土壌(ジャーガル)圃場における排水性改善技術や暖地2年4作水田輪作体系における水稲直播技術の開発に従事しました。また,ドローンを利用したリモートセンシングや防除技術の開発にも取り組みました。2026年10月1日からは,琉球大学農学部の教員として学生たちとともにスマート農機を活用した亜熱帯地域の安定生産技術に関する研究開発に挑戦します。

現在の所属組織 【 表示 / 非表示 】

  • 専任   琉球大学   農学部   地域農業工学科   准教授  

出身大学 【 表示 / 非表示 】

  •  
    -
    1997年03月

    琉球大学   農学部   生物生産学科   卒業

出身大学院 【 表示 / 非表示 】

  • 2000年04月
    -
    2003年09月

    鹿児島大学  連合農学研究科  生物環境保全科学専攻  博士課程  修了

取得学位 【 表示 / 非表示 】

  • 鹿児島大学 -  博士(農学)  環境・農学 / 農業環境工学、農業情報工学

職歴 【 表示 / 非表示 】

  • 2003年10月
    -
    2026年09月

      国立研究開発法人農業・食品産業技術総合研究機構  

  • 2026年10月
    -
    継続中

      琉球大学  

所属学会・委員会 【 表示 / 非表示 】

  • 2005年03月
    -
    継続中
     

    日本農作業学会

  • 1998年04月
    -
    継続中
     

    農業食料工学会

  • 1998年09月
    -
    継続中
     

    九州農業食料工学会

  • 1997年10月
    -
    継続中
     

    テラメカニックス研究会

研究キーワード 【 表示 / 非表示 】

  • 農業機械学・スマート農業・テラメカニックス

  • 農業食料工学・生物生産学

研究分野 【 表示 / 非表示 】

  • 環境・農学 / 農業環境工学、農業情報工学

取得資格 【 表示 / 非表示 】

  • 高等学校教諭専修免許

  • 普通自動車免許(一種)

  • 大型特種自動車免許(一種)

  • 自動二輪車免許

  • 二等無人航空機操縦士免許

全件表示 >>

主たる研究テーマ 【 表示 / 非表示 】

  • スマート農機を活用した亜熱帯地域の安定生産技術に関する研究

学位論文 【 表示 / 非表示 】

  • 車輪のけん引力発生メカニズムとけん引性能予測に関する研究

    2003年09月 

論文 【 表示 / 非表示 】

  • 西南暖地における水田輪作体系への子実トウモロコシ導入の可能性

    松尾 直樹, 深見 公一郎, 高橋 仁康, 中野 恵子 (担当範囲: 主に実験と論文執筆に貢献)

    Japanese Journal of Crop Science ( Crop Science Society of Japan )  95 ( 3 ) 205 - 215   2026年07月 [ 査読有り ]

    掲載種別: 研究論文(学術雑誌)

     概要を見る

    省力的に栽培可能な作物として,北日本を中心に 1 年 1 作の単作水田輪作体系に子実トウモロコシの導入事例が増えているが,西南暖地の 2 年 3 作あるいは 2 年 4 作の多毛作水田輪作体系における知見は少ない.そこで,本研究では,多毛作地帯に本作物を導入することを想定し,春播きと夏播き栽培における収量を評価した.試験 1 では春播き栽培と夏播き栽培における収量比較を,試験 2 では春播き栽培において晩生品種ほど多収になるかを,試験 3 では夏播き栽培において品種の早晩性と栽植密度が収量におよぼす影響を検討した.坪刈りは機械収穫の目安となる子実水分が 30%以下になったのを確認後に実施した.3 年平均した春播き栽培と夏播き栽培の収量はそれぞれ 908 と522 g/m2 であった(試験 1).春播き栽培では供試した相対熟度(RM) 106,115,125 の 3 品種のうち RM115 の品種が2 か年とも最多収となり 1000 g/m2 以上となる年があった(試験 2).春播き栽培における収量の変動要因が生殖生長初期の日照不足であること,RM125 程度の晩生品種は生育量が旺盛になり倒伏による減収リスクが高いことが示唆された.夏播き栽培では登熟可能な範囲で晩生の品種が多収になり,栽植密度を 6.7 本 /m2 から 8.3 本 /m2 に増やすことで約 25%増収したが,収量は最大で 697~772 g/m2 であり,春播き栽培の収量水準(1000 g/m2 程度)には至らなかった(試験 3).子実トウモロコシは省力栽培が可能かつ春播き栽培で多収となることから,今後さらなる規模拡大が想定される多毛作大規模経営体向けに,本作物の春播き栽培を導入した新たな輪作体系を構築していく必要がある.

  • Field-Validated Drone-Based Precision Control of the Invasive Apple Snail (Pomacea canaliculata) in Rice Paddy Fields: Chemical Reduction and Yield Preservation

    Senlin Guan, Kimiyasu Takahashi, Shuichi Watanabe, Koichiro Fukami, Hiroyuki Obanawa, Keita Ono (担当範囲: 主に実験と論文執筆に貢献)

    Drones ( MDPI AG )  10 ( 3 ) 176 - 176   2026年03月 [ 査読有り ]

    掲載種別: 研究論文(学術雑誌)

     概要を見る

    Apple snail infestation poses a persistent threat to rice production in open-field environments, where long-term coexistence with this species is unavoidable. This study presents a drone-based precision control approach that integrates high-resolution micro-topographic mapping with site-specific pesticide application. A lightweight mapping unmanned aerial vehicle was deployed to produce centimeter-level microtopographic data across paddy fields, facilitating the identification of deep-water areas preferred by apple snails. From these elevation-derived water risk patterns, prescription maps were generated to guide downstream management decisions, and agricultural drones equipped for granular application subsequently performed targeted pesticide delivery only in these high-risk areas. Over 2 years of field experiments, the proposed method achieved rice yields comparable to those under conventional management while reducing pesticide use by 44.1–63.0%, with lower estimated crop damage in regions with high apple snail occurrence. Designed with robustness and scalability in mind, the system demonstrated considerable potential for practical implementation in general farming households and broader applications in precision pest management.

  • Drone Delivery of Insecticide Is Uneven Yet Sufficiently Controls Subterranean Weevils Infesting Sweet Potato Plants.

    Koichiro Fukami, Kimiyasu Takahashi, Senlin Guan, Katsuya Ichinose (担当範囲: 研究計画・実験・解析・論文執筆)

    Plants (Basel, Switzerland) ( MDPI AG )  14 ( 22 )   2025年11月 [ 査読有り ]

    掲載種別: 研究論文(学術雑誌)

     概要を見る

    Drone insecticide spraying is generating increasing concern and interest among academics and the public. However, the differences in the quantity of insecticide delivered by this method, and its efficacy in pest control for individual plants, remain to be evaluated. We examined the distribution and quantity of an insecticide sprayed on sweet potato plants and the method's efficacy in controlling a subterranean weevil infestation. To evaluate delivery patterns, water-sensitive paper was placed on the canopy of the plants, and the insecticide was sprayed from a drone at the registered concentration. Although there was minimal deflection of flight paths (under crosswinds ≤ 3.0 m/s), the distribution varied across the field. The quantity administered was within the regulated range for the insecticide. Efficacy was not significantly influenced by either the quantity administered or pattern of spraying, and the drone application resulted in an equivalent level of control as a conventional ground-based application. While the quantity of the insecticide applied to the canopy was uneven, the method's efficacy was satisfactory at the field scale. These findings can be used to develop safe and cost-effective methods for the drone application of pesticides.

  • Measurement accuracy of CAN data acquired from tractors and correlation analysis under operating conditions

    Keita ONO, Koichiro FUKAMI, Kimiyasu TAKAHASHI (担当範囲: 研究計画・実験・解析・論文執筆)

    Engineering in Agriculture, Environment and Food ( Asian Agricultural and Biological Engineering Association )  18 ( 3 ) 133 - 141   2025年10月 [ 査読有り ]

    掲載種別: 研究論文(学術雑誌)

     概要を見る

    Working (tillage and sowing) depth is critical for crop growth, and a simple yet highly accurate technique for measuring in-field working depth is necessary to achieve uniform growth and increased yield. Therefore, we devised a depth estimation and control system based on tractor controller area network (CAN) data, validated the CAN data accuracy, and built depth estimation models. The relative error between the CAN-derived forward speed and the measured speed was low at −1.21–2.21 %. Additionally, we built a model to estimate the measured value of the power take off speed from the CAN value with R2 = 0.99. The depth estimation model showed a strong correlation between hitch height and tillage/sowing depth (R = 0.99 and 0.86, respectively).

  • Agricultural Drone-Based Variable-Rate N Application for Regulating Wheat Protein Content

    Senlin Guan, Yumi Shimazaki, Kimiyasu Takahashi, Hitoshi Kato, Koichiro Fukami, Shuichi Watanabe (担当範囲: 主に実験と論文執筆に貢献)

    Drones ( MDPI AG )  9 ( 4 ) 310 - 310   2025年04月 [ 査読有り ]

    掲載種別: 研究論文(学術雑誌)

     概要を見る

    Implementing a variable-rate application (VRA) of fertilization based on real-time crop growth status reduces costs and enhances work efficiency. However, the technical challenges associated with obtaining accurate growth-distribution maps and applying VRA, particularly with agricultural drones, remain underexplored. In this study, we specifically focused on agricultural drone-based VRA fertilization for regulating wheat protein content. First, normalized difference vegetation index (NDVI) distribution maps were obtained using multispectral images captured using a small unmanned aerial vehicle. Subsequently, a prescription map based on the NDVI values was generated to facilitate the implementation of VRA for fertilization. Continuous monitoring of changes in related vegetation indices was conducted from post-topdressing to harvest. Experimental results indicated that selecting targeted experimental survey areas based on different growth conditions can result in accurate predictions of the final yield. However, it is sill ineffective for predicting protein content or protein yield. Additionally, VRA fertilization with less fertilizer in high-NDVI areas and more fertilizer in low-NDVI areas showed no significant difference in final protein content or protein yield compared to conventional uniform fertilization. These findings provide reference data for advancing precision agriculture by addressing field-scale variability for high-quality and uniform production while presenting further research challenges.

全件表示 >>

著書 【 表示 / 非表示 】

  • 農業および園芸(100巻10号)

    養賢堂 ( 担当: 分担執筆 , 担当範囲: 降雨後の土壌でも適期を逸さず播種できる「畝立て乾田直播機」 )

    養賢堂  2025年10月 ( 担当ページ: p.853-858 )

  • 米麦改良

    全国米麦改良協会 ( 担当: 分担執筆 , 担当範囲: 畝立て同時乾田直播機の開発について )

    一般社団法人全国米麦改良協会  2025年03月

  • 特集子実用トウモロコシ栽培から収穫・調製まで

    農山漁村文化協会 ( 担当: 分担執筆 , 担当範囲: 振動ローラ式水稲乾田直播 )

    農山漁村文化協会  2023年02月 ( ページ数: 271p )

  • 農業食料工学ハンドブック = Handbook of agricultural machinery and food engineers

    農業食料工学会 ( 担当: 分担執筆 , 担当範囲: 7編4.1.3,4.3.1~4.3.3 )

    コロナ社  2020年04月 ( ページ数: xii, 1092p )

  • 特集転作ダイズの増収技術

    農山漁村文化協会 ( 担当: 分担執筆 , 担当範囲: 暖地2毛作-水稲で鉄コーティング種子のショットガン直播,ダイズで耕起一工程播種,ムギで表面散播栽培など )

    農山漁村文化協会  2013年01月 ( ページ数: 287p )

全件表示 >>

MISC(その他業績・査読無し論文等) 【 表示 / 非表示 】

  • 畝立て乾田直播機の開発

    深見公一郎

    農業食料工学会誌   87 ( 1 )   2025年


    J-GLOBAL

  • 畝立て直播機による子実トウモロコシ播種における作業速度の影響

    深見公一郎, 小野渓太, 松尾直樹, 高橋仁康

    農作業研究   60   2025年


    J-GLOBAL

  • トラクタとドローンデータを利用した単回帰分析による最適作業深の推定

    小野渓太, 深見公一郎, 官森林, 高橋仁康

    農作業研究   60   2025年


    J-GLOBAL

  • 水稲生育診断を用いたドローン可変追肥技術

    官森林, 渡邊修一, 高橋仁康, 深見公一郎

    農作業研究   59   2024年


    J-GLOBAL

  • 異なる圃場条件下での耕うん・播種作業時のトラクタログ解析

    小野渓太, 深見公一郎, 官森林, 高橋仁康

    農業食料工学会年次大会講演要旨(CD-ROM)   82nd   2024年


    J-GLOBAL

全件表示 >>

特許等知的財産 【 表示 / 非表示 】

  • 作業深さ関連処理システム、解析装置および作業深さ関連処理方法

    特願 特願2024-152029  (2024年09月04日)

    特開 特開2026-047534  (2026年03月16日)

    小野 渓太, 深見 公一郎, 高橋 仁康, 官 森林

    J-GLOBAL

  • 刈取機用カバー及びカバー付き刈取機

    特願 特願2024-029972  (2024年02月29日)

    特開 特開2025-132426  (2025年09月10日)

    深見 公一郎, 松尾 直樹, 三池 輝幸, 本部 朗利

    J-GLOBAL

  • 情報処理装置、情報処理システム、情報処理方法、プログラム、および情報生成方法

    特願 特願2023-065902  (2023年04月13日)

    特開 特開2024-152016  (2024年10月25日)

    深見 公一郎, 高橋 仁康

    J-GLOBAL

  • 支援装置、および土壌推定装置

    特願 特願2022-009497  (2022年01月25日)

    特開 特開2022-115826  (2022年08月09日)

    特許 特許第7660901号  (2025年04月04日)

    中野 恵子, 高橋 仁康, 深見 公一郎

    J-GLOBAL

  • 食害推定装置及び食害推定システム

    特願 特願2021-050211  (2021年03月24日)

    特開 特開2022-148500  (2022年10月06日)

    特許 特許第7514536号  (2024年07月03日)

    高橋 仁康, 官 森林, 深見 公一郎

    J-GLOBAL

全件表示 >>

学術関係受賞 【 表示 / 非表示 】

  • NARO RESEARCH PRIZE 2025

    2025年09月   農研機構   排⽔対策と⾼能率化を両⽴す る画期的新播種技術「ディス ク式⾼速⼀⼯程播種法」の開発  

    受賞者: 松尾直樹, 高橋仁康, 深見公一郎, 中野恵子

  • 2025年度日本作物学会 論文賞

    2025年03月   日本作物学会   逆転ロータリを活用した一工程浅耕播種による北部九州における気象リスク下でのダイズの減収抑制効果  

    受賞者: 松尾直樹, 中野恵子, 大段秀記, 深見公一郎, 高橋仁康

  • ISMAB 2024・最優秀講演賞

    2024年09月   International Symposium on Machinery and Mechatronics for Agriculture and Biosystems Engineering   Validation of DEM model for corn threshing through kernel distribution in the threshing chamber of a combine harvester for multicrops  

    受賞者: 大塚望実, 平井康丸, 深見公一郎, 岡安崇史, 高橋仁康, 光岡宗司

  • 2024年日本農業工学会 学会賞・新農林社賞

    2024年05月   日本農業工学会   九州・沖縄地域における土地利用型作物の機械化研究  

    受賞者: 深見 公一郎

  • 2023年農業技術10大ニュース(TOPIC2)

    2023年12月   農林水産技術会議   雨が降っても安心! -畝立て同時乾田直播機を開発-  

    受賞者: 深見 公一郎他

全件表示 >>

科研費獲得情報 【 表示 / 非表示 】

  • 子実コーンの安全高能率収穫を実現する国産汎用コンバインの作業条件と設計指針の提示

    基盤研究(C)

    課題番号: 23K05479

    研究期間: 2023年04月  -  2026年03月 

    代表者: 深見 公一郎  研究分担者: 平井 康丸, 高橋 仁康

    直接経費: 3,600,000(円)  間接経費: 1,080,000(円)  金額合計: 4,680,000(円)

  • ハイブリッドペトリネットとディープラーニングを用いた作物生育モデリングと実証

    基盤研究(C)

    課題番号: 18K05914

    研究期間: 2018年04月  -  2021年03月 

    代表者: 官 森林  研究分担者: 鹿内 健志, 深見 公一郎, 名嘉村 盛和

    直接経費: 3,300,000(円)  間接経費: 990,000(円)  金額合計: 4,290,000(円)

     概要を見る

    過去の草丈・茎数・葉数などの生育指標データを利用し、ハイブリッドペトリネット用いて稲の基本生育モデルを作成した。また、ハイブリッドペトリネットのシミュレーション計算を行い、生育日数に対する草丈、茎数、葉数などの経時変化を明らかにした。 基本生育モデルを実際の作物へ適用させるために、2018年春から直播水稲に関する上記生育指標データ、同年冬から麦(2019年5月収穫)の生育指標データに加えて地温・水分などの環境影響要素データを測定・蓄積してきた。九州沖縄農業研究センター試験圃場と福岡県生産者圃場においては、1週間間隔でマルチスペクトルカメラが搭載されたドローン(DJI Phantom 4 + Parrot Sequoia)によるリモートセンシング試験を行った。沖縄県農業研究センター試験圃場では1~2週間間隔で可視光カメラのみが搭載されたドローン(DJI Phantom 4)による空撮試験を実施した。また、空撮画像からサトウキビ草丈を推定するために、トータルステーション測量機器を利用し、試験圃場高さの測量を行った。可視光カメラとマルチスペクトルカメラで取得した画像は、稲・大豆・麦に関する空撮画像と生育変化(草丈、正規化植生指数NDVIなど)の時系列データとして蓄積し、解析した。 「ハイブリッドペトリネットを用いた作物生育モデリング」に関連する「軽量型ドローンによる稲と麦の高解像度NDVI、施肥水準と収量の相関性」と「サトウキビ生産法人における実際のスケジューリング問題とその解法」についての論文2本が国際誌ジャーナルへ公表された。

  • 準天頂衛星を利用したマルチコプター自動飛行による超効率型農業経営のモデル研究

    基盤研究(C)

    課題番号: 15K07683

    研究期間: 2015年04月  -  2019年03月 

    代表者: 長谷川 克也  研究分担者: 深見 公一郎 , 岡安 崇史 , 粂井 康宏

    直接経費: 3,800,000(円)  間接経費: 1,140,000(円)  金額合計: 4,940,000(円)

     概要を見る

    ドローンの農業利用は農業情報の取得と、農薬散布などの農作業の2つに大きく分かれる。マルチコプターといわれる4枚以上の回転翼を持つドローンは操縦の簡易さから爆発的に普及し飛行性能の進歩も著しい。しかし、導入コストと運用費用が高く急速な普及とはなっていない。本研究では農業経営へのコストを考慮し、マルチコプターだけではなく、農業情報の取得に固定翼機、水田初期除草にプロペラボート、除草作業にロボットカーなど、多様なシステムの協調により効率的農業へのアプローチを行った。

  • 水稲乾田直播栽培における振動ローラ加速度応答に基づく圃場透水性制御技術

    若手研究(B)

    課題番号: 25850175

    研究期間: 2013年04月  -  2016年03月 

    代表者: 深見 公一郎  研究分担者: 椋木 俊文 , 中野 恵子 , 岡安 崇史 , 松尾 直樹 , 土屋 史紀 , 佐々木 豊 , 稲葉 敏樹 , 広間 達夫

    直接経費: 2,900,000(円)  間接経費: 870,000(円)  金額合計: 3,770,000(円)

     概要を見る

    本研究では,ローラ鎮圧前の土壌が塑性限界(土を練り,すりガラス上で直径3mmのひも状にできる時の土壌水分状態)以上の場合,圃場の漏水を十分に防止できることを実証した。その時の土壌構造は,不十分な場合に比べて空隙形状が扁平になり,全空隙率が少なく,逆に小さな空隙の割合が多くなった。一方,ローラの振動加速度の上下方向の主要周波数成分(MFC)の振幅が圃場の漏水量の低減に伴って増加したことから,振動ローラの加速度応答から漏水防止効果をある程度推定できることが示された。

共同研究実施実績 【 表示 / 非表示 】

SDGs 【 表示 / 非表示 】

  • スマート農機を活用した亜熱帯地域の安定生産技術に関する研究